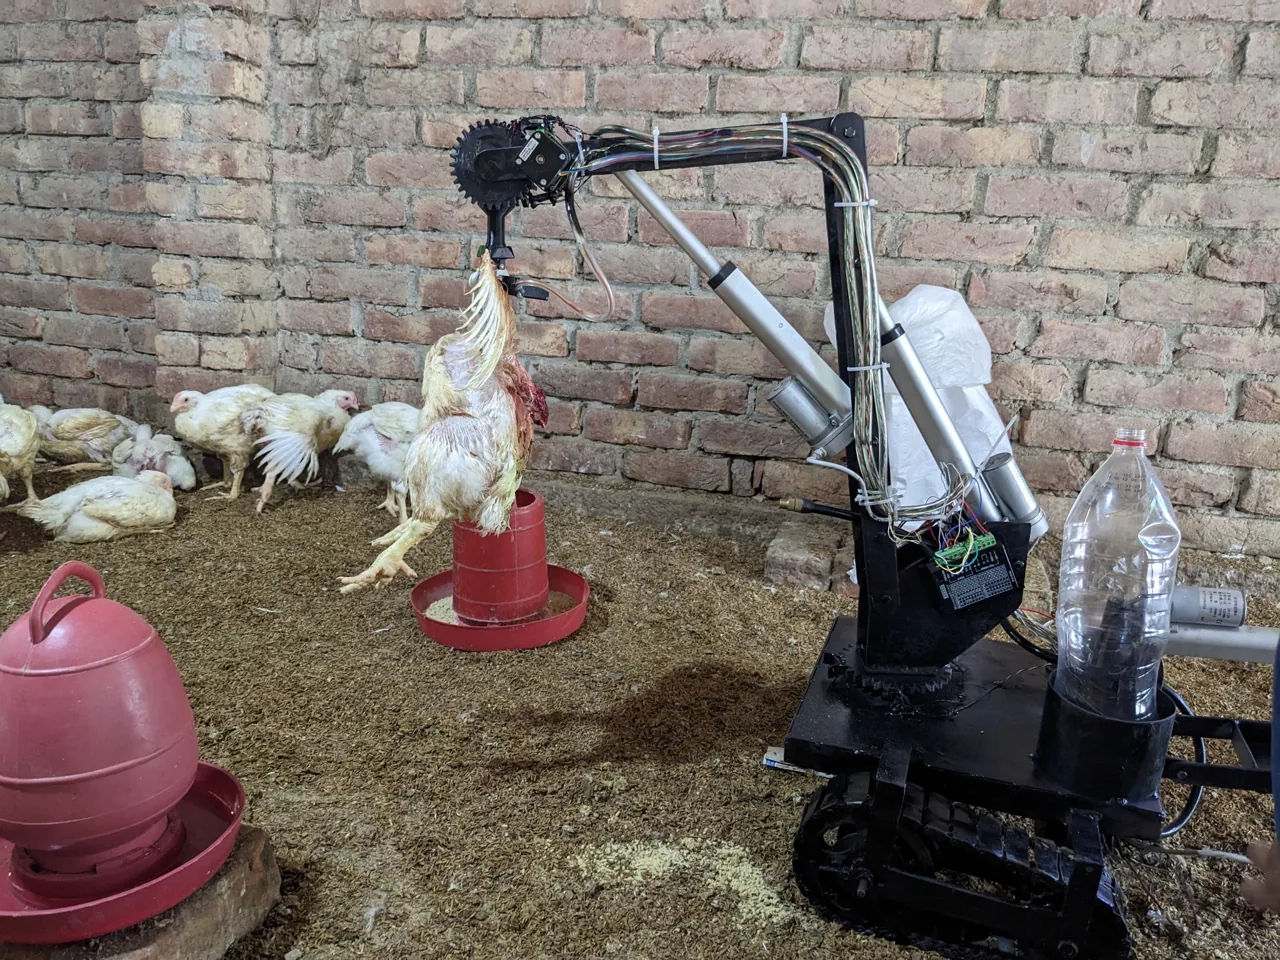
The next version starts with the last one
The poultry robot has already moved from manual operation to semi-autonomous work. I am now developing its next extension toward greater autonomy. It is not a new project disconnected from the earlier versions: it carries forward the lessons from the chassis, manipulator, embedded control and vision-integration work.